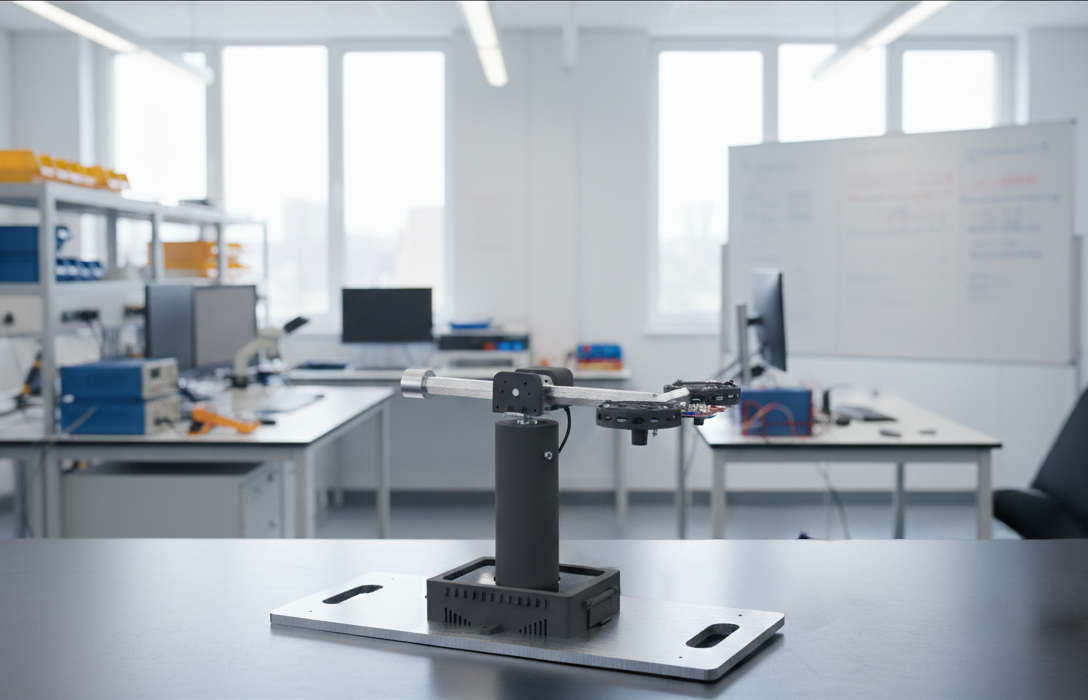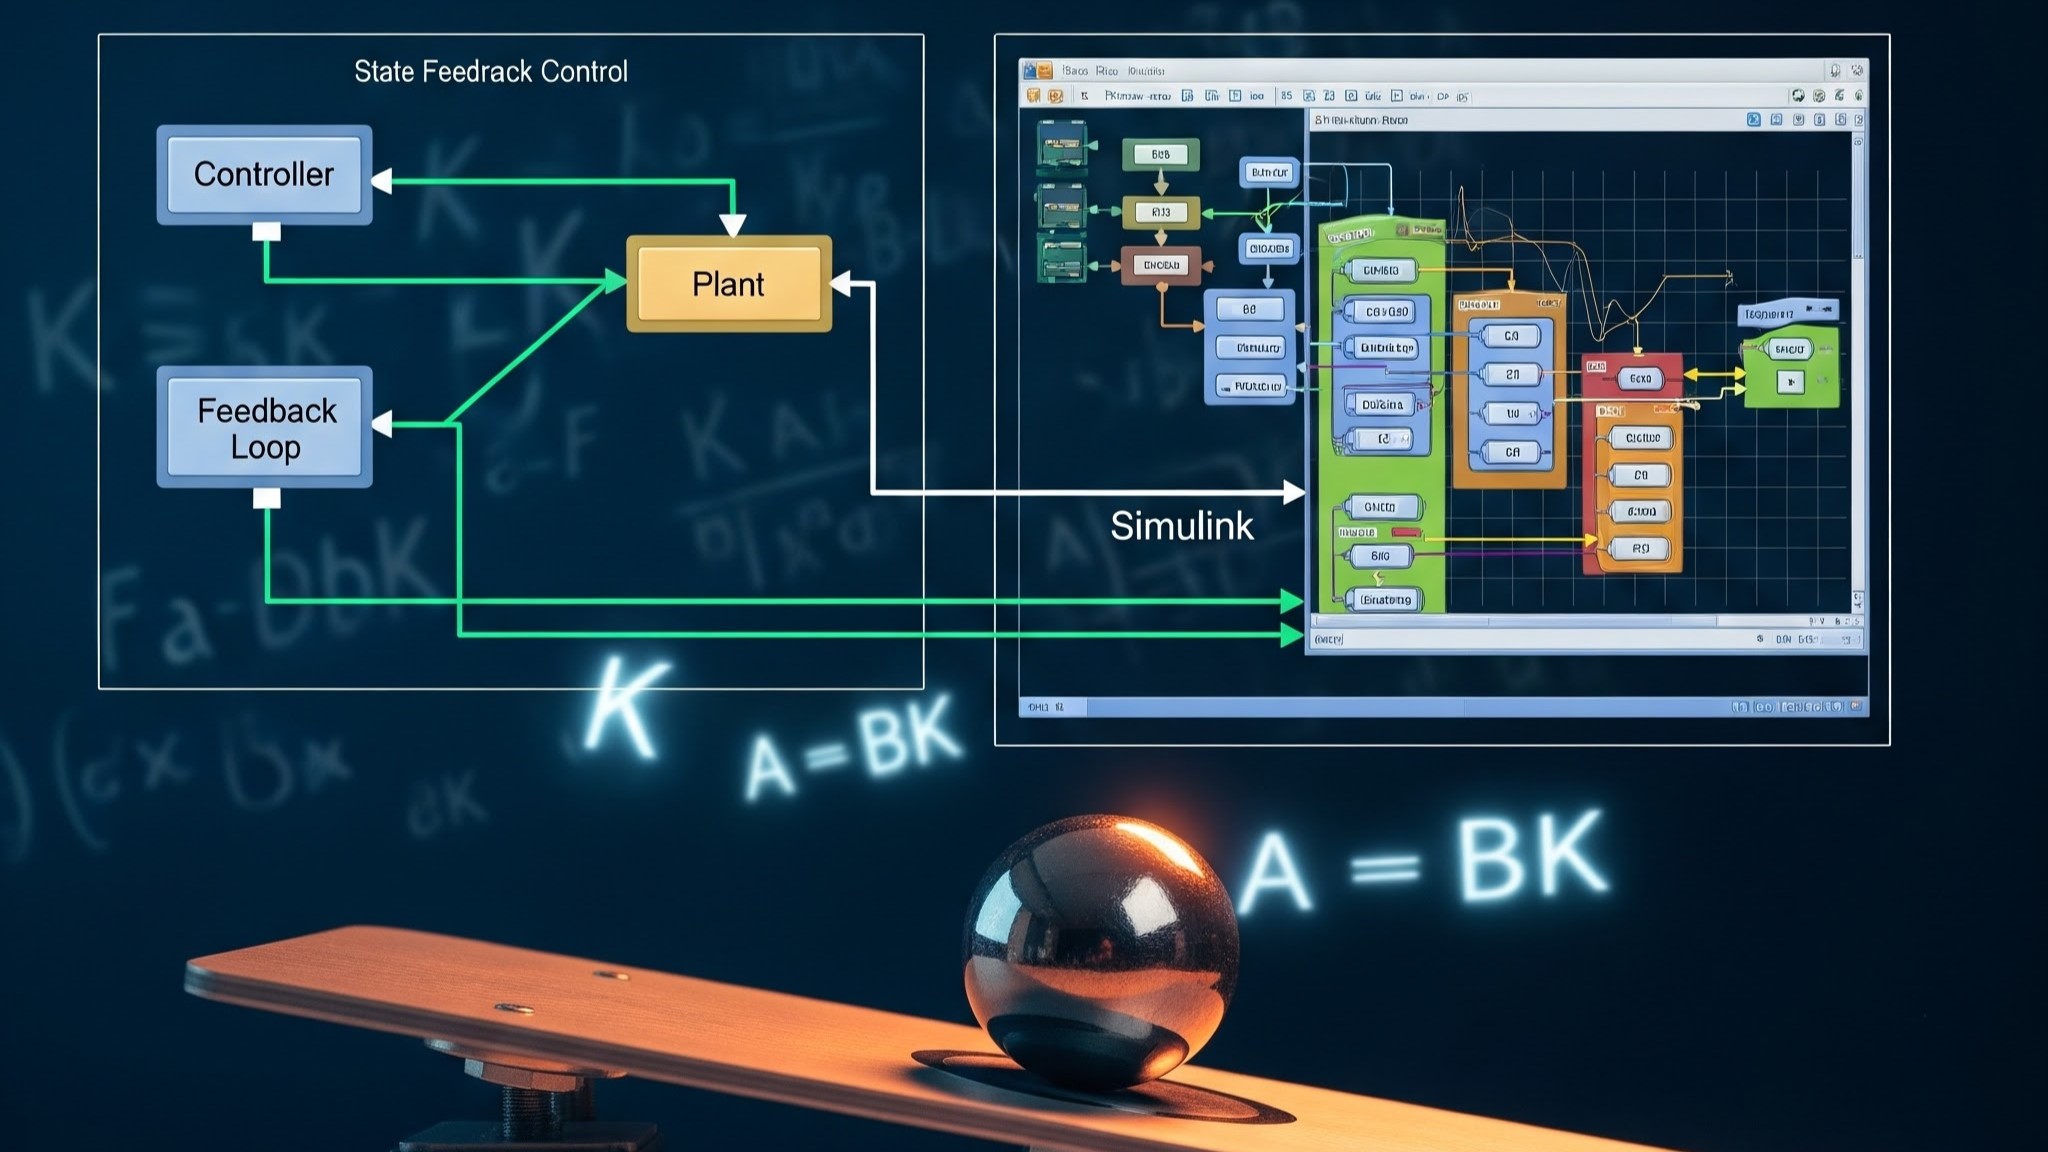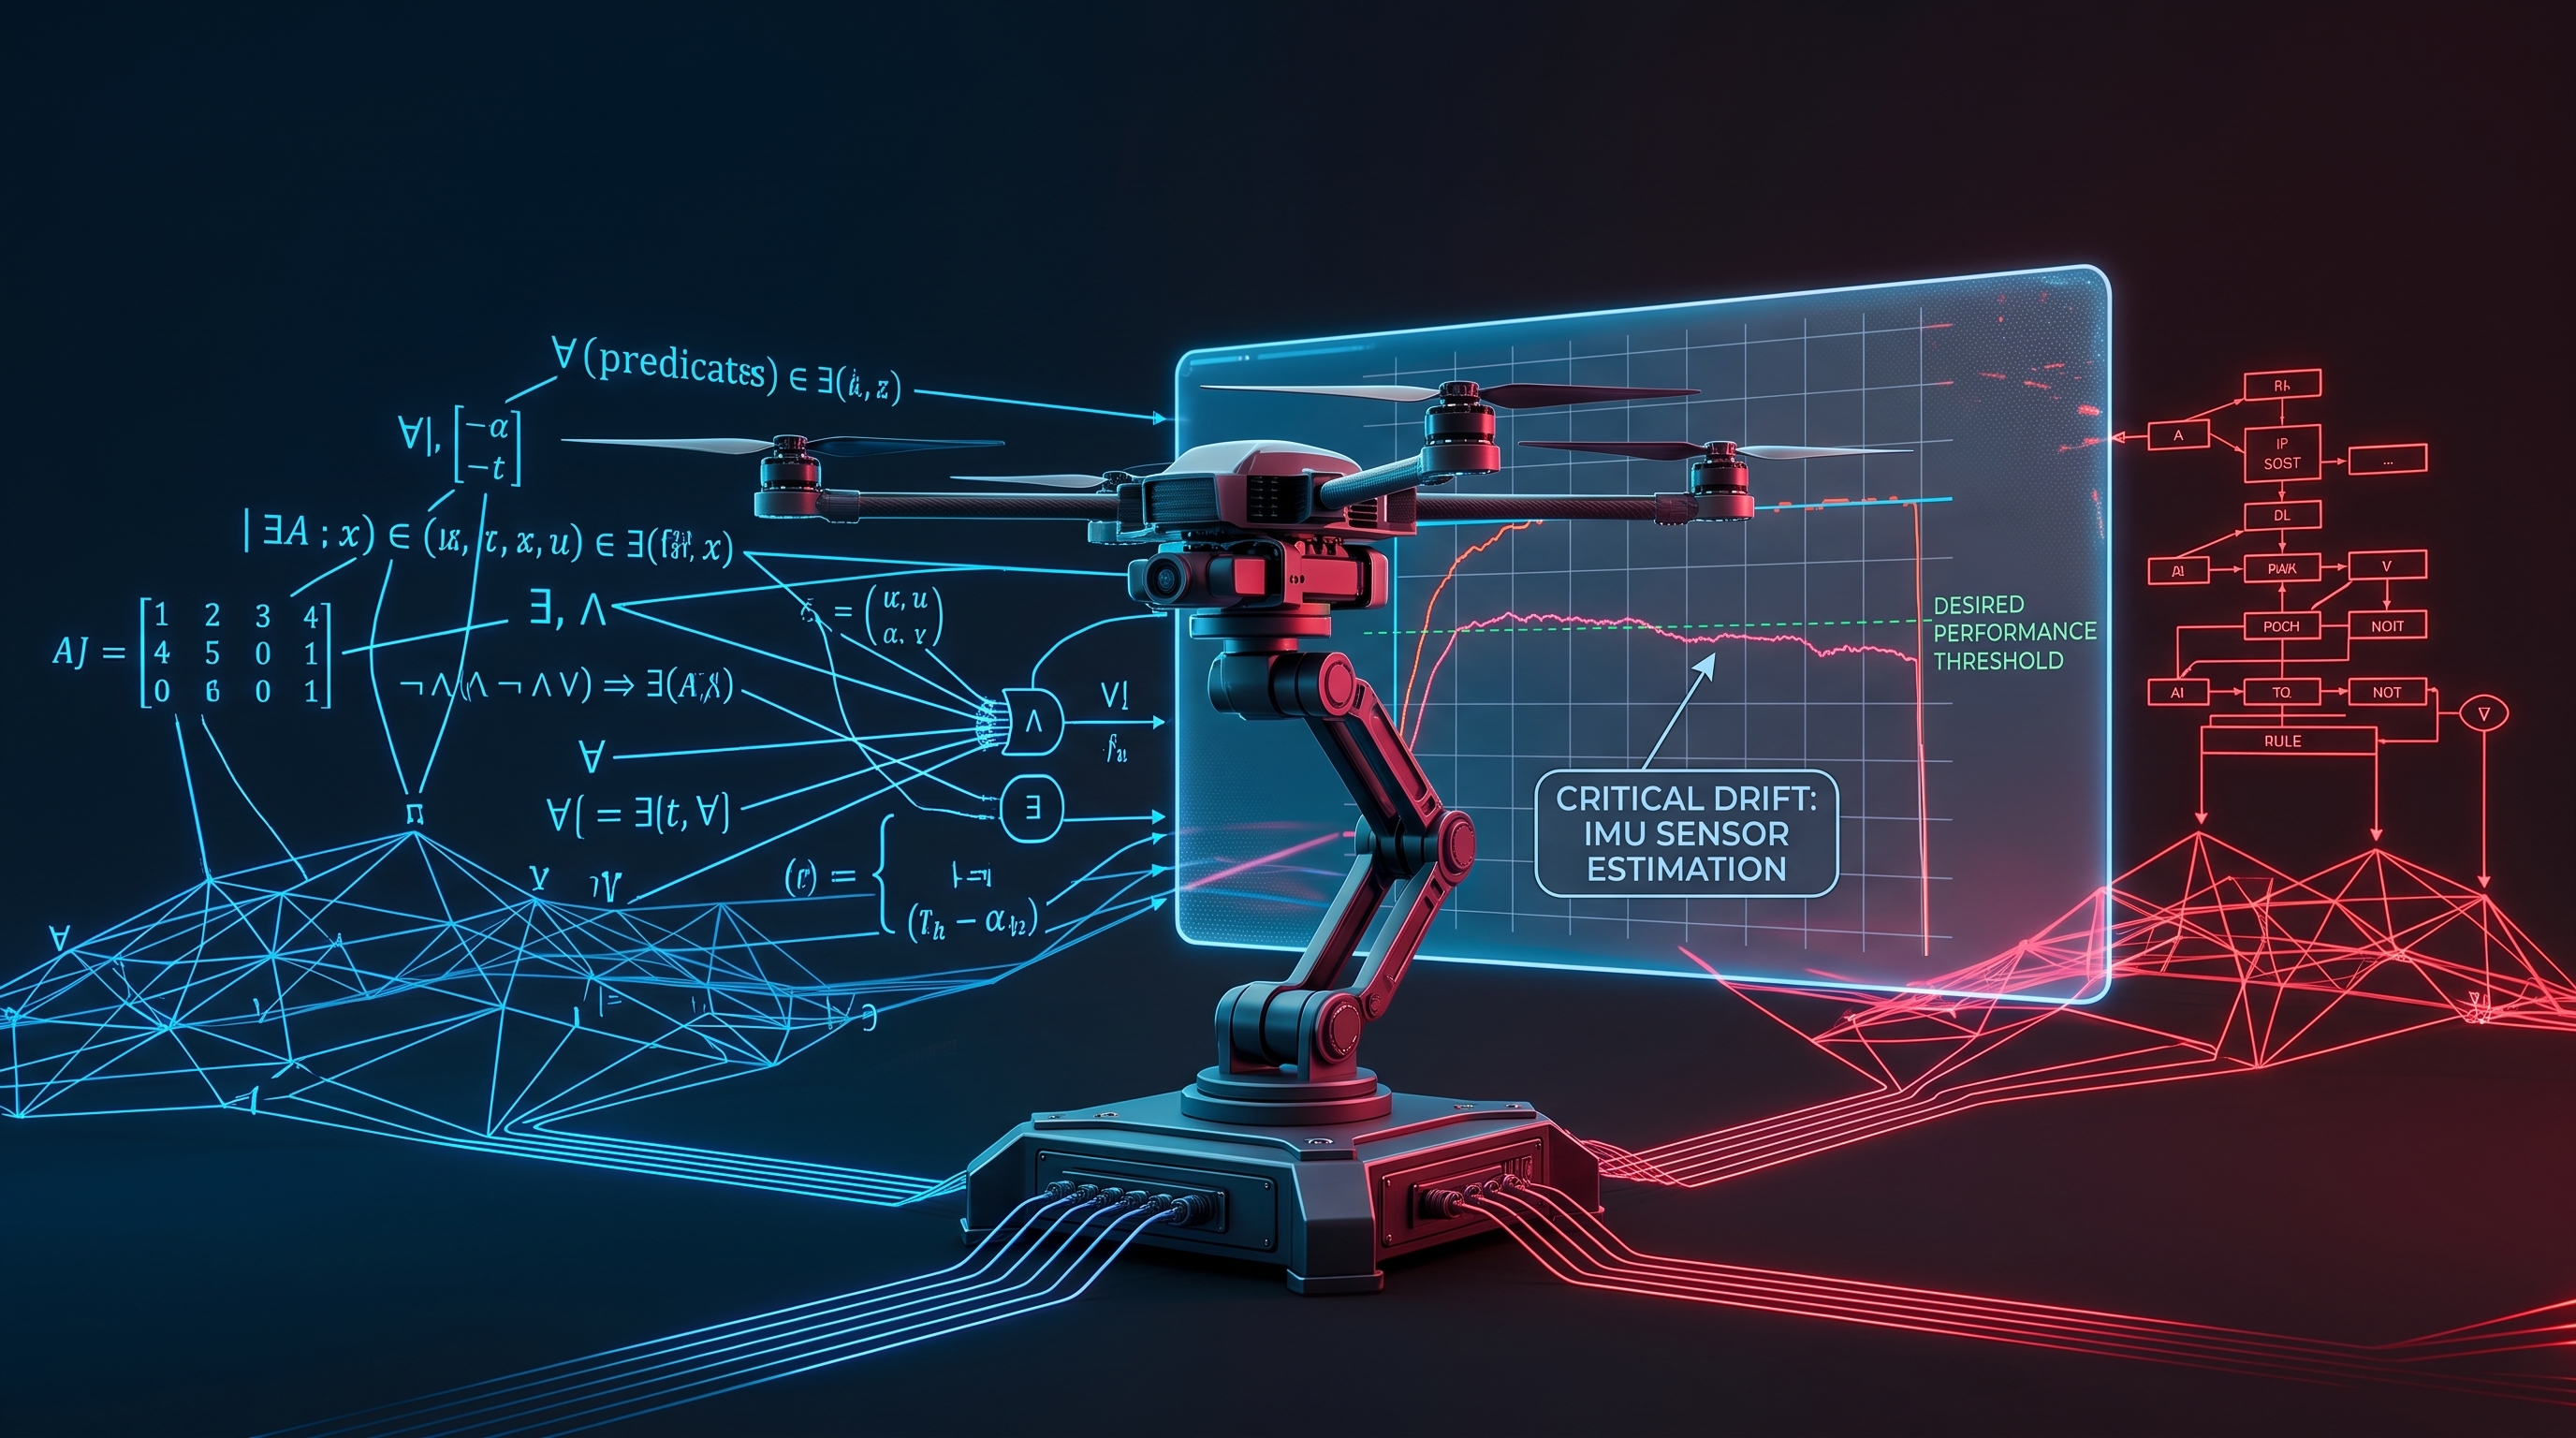
This blog post addresses sensor drift in the BNO055 IMU used on the Acrome 3-DoF Copter, driven by motor vibration and magnetic interference. While conventional Kalman filtering handles Gaussian noise, it struggles with structured, nonlinear residuals. To overcome this, the paper proposes a hybrid workflow integrating physical calibration, baseline estimation, and data-driven symbolic AI via OpenMathAI.